Generative AI for industrial inspection
Controllable defect synthesis and few-shot anomaly detection for quality control in manufacturing.
Visual quality control needs examples of defects, yet good factories produce very few of them. This work tackles the data problem from two sides: generating realistic defects to train detectors, and building detectors that need only a handful of examples.
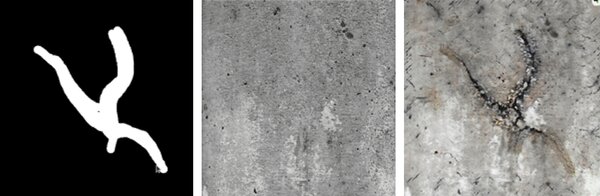
Synthetic defects with COIGAN
COIGAN (Controllable Object Inpainting through Generative Adversarial Network) inpaints defects of a chosen shape and position onto clean images, producing labelled training data for defect detectors. The method was presented at IEEE ICRA 2025 (Biancucci et al., 2025), and its application to anomaly detection was presented at the Ital-IA 2025 workshop “AI per la Robotica” (Narang et al., 2025).


Robotic vision for plastics and packaging
Next-generation robotic vision systems for quality assurance in plastics and packaging were presented at the European Robotics Forum 2024 (Galdelli et al., 2024).
InfinityRobotics (2026)
In the Italian national project InfinityRobotics, I developed and deployed computer vision models with few-shot anomaly detection to improve a manufacturer’s production capacity. The system identifies defects early in the production line from minimal training samples, enabling real-time quality control without large labelled datasets. This reduced material waste and improved product consistency, lowering scrap rates and energy consumption per unit produced.
References
2025
- ICRA
 COIGAN: Controllable Object Inpainting Through Generative Adversarial Network for Defect Synthesis in Data AugmentationIn 2025 IEEE International Conference on Robotics and Automation (ICRA), 2025
- Ital-IAControllable object inpainting through generative adversarial network applied to anomaly detectionIn Workshop “AI per la Robotica”, Ital-IA 2025 – Convegno Nazionale CINI sull’Intelligenza Artificiale, 2025

2024
- ERFNext-Generation Robotic Vision Systems for Quality Assurance in Plastics and PackagingIn European Robotics Forum, 2024
